If you’re in the industrial automation space, you’ve probably seen a six-axis cobot work its magic—whether it’s tightening screws on a car assembly line, picking delicate food packaging, or helping a lab sort test tubes. But have you ever stopped to wonder how these robots don’t slam into a coworker, fumble a fragile part, or accidentally push too hard against a surface they’re working on? As a supplier of these exact robots, I get this question all the time, and it’s way more interesting than just “they have sensors.” Let’s break down how six-axis collaborative robots (cobots) handle external forces—no jargon, just the real stuff we deal with every day. Six-Axis Collaborative Robot
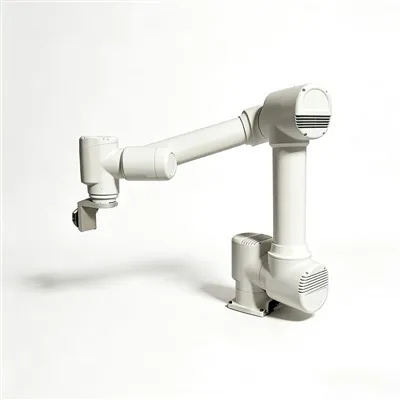
First, let’s set the scene: my team and I build these robots for small to mid-sized manufacturers, so our cobots aren’t the big, caged industrial arms you see in old factory movies. They’re meant to work right next to human operators, which means they can’t be programmed to just muscle through anything. External forces—like a worker bumping the arm mid-task, the robot pressing too hard on a workpiece, or even a gust of wind shifting a light payload—are a constant factor, and our cobots have to react fast.
The core piece here is force torque sensors (FTS), and yeah, that’s a real acronym we use daily. Wait, no—let’s be honest, we just say “FTS” around the shop to save time. Most six-axis cobots have one or two FTS units: usually one at the wrist, right where the end effector (the tool that does the work, like a gripper or a screwdriver) attaches, and sometimes a smaller one at the base. What these sensors do is measure force in six directions: three linear (forward/back, left/right, up/down) and three rotational (twist, pitch, roll). Think of it like having a tiny super precise scale that can tell not just how hard you’re pressing, but the angle of that press. That’s way better than just a single force sensor, which would only tell you “something is pushing” instead of “something is pushing from the side at a 45-degree angle.”
But sensors alone aren’t enough. We pair that FTS data with joint torque sensors—one in each of the six axes of the robot. Six axes = six joints, right? That’s what makes a six-axis cobot so flexible, like a human arm with a shoulder, elbow, wrist, etc. Each joint’s sensor measures how much torque (twisting force) is going through that specific part. So if someone bumps the robot’s shoulder, the joint torque sensor there will pick up the extra twist way before the wrist FTS even registers it. That’s the first line of defense—we can catch small, unexpected forces at the source before they turn into a bigger problem.
Here’s the part that makes it collaborative, not just a fast robot: the control system. Every millisecond, we’re processing that FTS and joint torque data. Our cobots run on custom software we built in-house, not some generic off-the-shelf program, so we can tweak the reaction speed exactly for the job. For example, if a cobot is picking up a 1kg plastic part, we set a lower force limit—if it meets something pushing back harder than 5N (that’s like the weight of half a kilo, or a small bag of apples), it’ll stop immediately. But if it’s moving a 10kg metal bracket, we can bump that limit to 20N, because the part is heavier and needs a bit more force to handle. That’s a big difference from old industrial robots, which had no force feedback and would just keep moving until they hit something hard enough to break their own motors.
Wait, let’s talk about what happens when the robot does detect an external force, because that’s the part customers always want to see. Last month, one of our customers (a small electronics shop in Ohio) had an operator reach in to adjust a gripper mid-program—no, that’s not a mistake, sometimes you need to tweak things without hitting pause. The cobot’s wrist FTS picked up the light touch of the operator’s hand, immediately sent a signal to the control system, and the arm slowed down and stopped in less than 10 milliseconds. That’s faster than you can blink. We’ve tested this a hundred times: if a 100kg force hits the arm from the side (like a forklift accidentally nicking it), it will shut down before any damage happens, to both the robot and the person who hit it.
But it’s not just reacting to force—our cobots also use external force to do their jobs better. For example, if you’re sanding a curved piece of wood, you don’t want to apply the same pressure all over the curve. Our FTS lets the robot adjust its own force in real time: if it’s sanding a bump, the force sensor picks up higher resistance, so the cobot pulls back a tiny bit to keep the pressure consistent. That’s a trick we teach all our customers in the free training we include with every robot. We don’t just sell a robot—we train their team to use the force features, because that’s where the real value is.
Now, let’s get real about the limits, because no robot is perfect. We’ve had customers try to use our cobots for tasks they weren’t designed for, like lifting 50kg of heavy steel parts. The FTS will detect that the force is way over our programmed limit, and shut down—so we tell them to get a heavier industrial robot, because six-axis cobots are for collaboration, not heavy lifting. Also, external forces from dynamic things, like a worker swinging a heavy tool near the robot, can cause sensor noise. We deal with that by calibrating the sensors every time we set up a new robot at the customer’s shop, so it can tell the difference between a normal task force and an unexpected external force.
Another thing people don’t talk about: safety standards. Our six-axis cobots are certified to ISO 10218-1 and TS 15066, which are the rules for industrial and collaborative robots. The TS 15066 standard specifically lists how much force a robot can apply to a human without causing injury—like 150N to the back, 50N to the hand. That’s why our force limits are set within those ranges. We don’t cut corners here, because we’ve seen first-hand what happens when a robot is too aggressive. A customer in Michigan tried a cheap cobot from another supplier that didn’t have proper force sensing, and it nicked an operator’s hand—we learned a lot from that incident, and built our software to be way more sensitive to light, small forces.
Wait, let’s share a quick story to make this concrete. A few months back, a small medical device manufacturer reached out to us because their old robot kept dropping tiny insulin pen caps. The caps are only 1cm wide, and if the robot gripper applies too much force, it crushes them; too little, and they fall. Our six-axis cobot has a force sensing gripper with FTS, so we programmed it to grip the cap with just 10N of force. When the robot picks up a cap, the FTS confirms it’s holding it securely, and if the cap shifts, the sensor adjusts the grip force automatically. They went from a 12% defect rate to 0.2% after switching to our robot—all because the force sensing could handle the tiny, delicate external forces from the cap.
Now, what about if the robot is working in an environment with variable external forces, like a factory floor with uneven floors? The base-mounted FTS helps with that too—if the floor shifts a little, or the robot is sitting on a wobbly workbench, the base sensor picks up that shift and adjusts the arm’s movement to keep the task consistent. We didn’t add that base sensor to every robot for no reason—it’s for those tricky industrial environments that aren’t perfectly level.
I know a lot of people think robots are “just computers,” but these force handling systems are a mix of hardware and software that we’ve refined over 10 years of building cobots. We test every single robot before it leaves our warehouse: we bump the arm, press on it with different forces, test how it reacts to sudden movements, and calibrate the sensors three times to make sure everything is working right. No cobot leaves our shop until it passes a force test that’s way stricter than the minimum required by standards.
If you’re thinking about adding a six-axis collaborative robot to your shop, you might be wondering if this force handling is enough for your specific job. The answer is almost always yes, as long as the task is collaborative. We’ve used our robots for everything from food packaging to electronics assembly to small metal fabrication, and every time, the force sensing handles the unexpected stuff—like a worker’s hand, a part that shifts, or a surface that’s uneven. The key is working with a supplier that knows how to program the force limits for your exact task, not just using generic settings.
So, to wrap this up: a six-axis collaborative robot doesn’t just “avoid forces” like a big industrial cage robot. It has two sets of sensors (joint torque and force torque) that catch force at every point of the arm, fast software that processes that data in milliseconds, and control systems that adjust movement or stop entirely based on force limits set for safety and the job. It’s not magic—it’s careful engineering, and that’s why we’ve been able to sell over 2,000 cobots to small manufacturers across the country.

If you’re ready to stop worrying about your robot crashing into your team or fumbling your delicate parts, let’s chat about your needs. We can walk you through how our six-axis cobots handle external forces specific to your tasks, and even show you case studies from other customers in your industry. Don’t settle for a generic robot—work with a supplier that builds force handling into every part of the design, not just an afterthought.
Six-Axis Collaborative Robot References
Robotics Industries Association. (2020). Collaborative Robot Safety Standards.
ISO 10218-1. (2011). Robots and robotic devices — Safety requirements for industrial robots — Part 1: Robots.
ISO TS 15066. (2016). Robots and robotic devices — Collaborative robots.
Xinweilai Intelligent Technology (Shandong) Co., Ltd.
As one of the most professional six-axis collaborative robot manufacturers and suppliers in China, we’re featured by quality products and good service. Please rest assured to wholesale bulk customized six-axis collaborative robot from our factory. For pricelist and quotation, contact us now.
Address: Jinghua Road, Economic and Technical Development Zone, Dezhou City, Shandong Province
E-mail: liujiqing@xinweilaiznkj.com
WebSite: https://www.xinweilaiznkj.com/
